Varen er på fjernlager, leveringstiden er 3-4 hverdage. Mere info
Leveringsmuligheder - Vælges ved checkout
Instabox - Pakkeboks
39,00
GLS - Pakkeshop
39,00
DAO - Hjemmelevering om natten og i de tidlige morgentimer
Perfekt til arbejdsdage - Levering inden kl. 06:00 - Klar når du vågner
45,00
GLS - Levering til hoveddøren
59,00
Afhentning i vores Pick-up point i Ringsted
19,00
Vis alle leveringsmuligheder (5)
DKK
531,00
ex. moms 424,80
Total inkl. fragt
570,00
Tilføj til liste
Funktionen kræver at man er logget ind. Opret en bruger og brug vores smarte liste system til at holde styr på fremtidige indkøb, faste indkøb eller ønskelister.
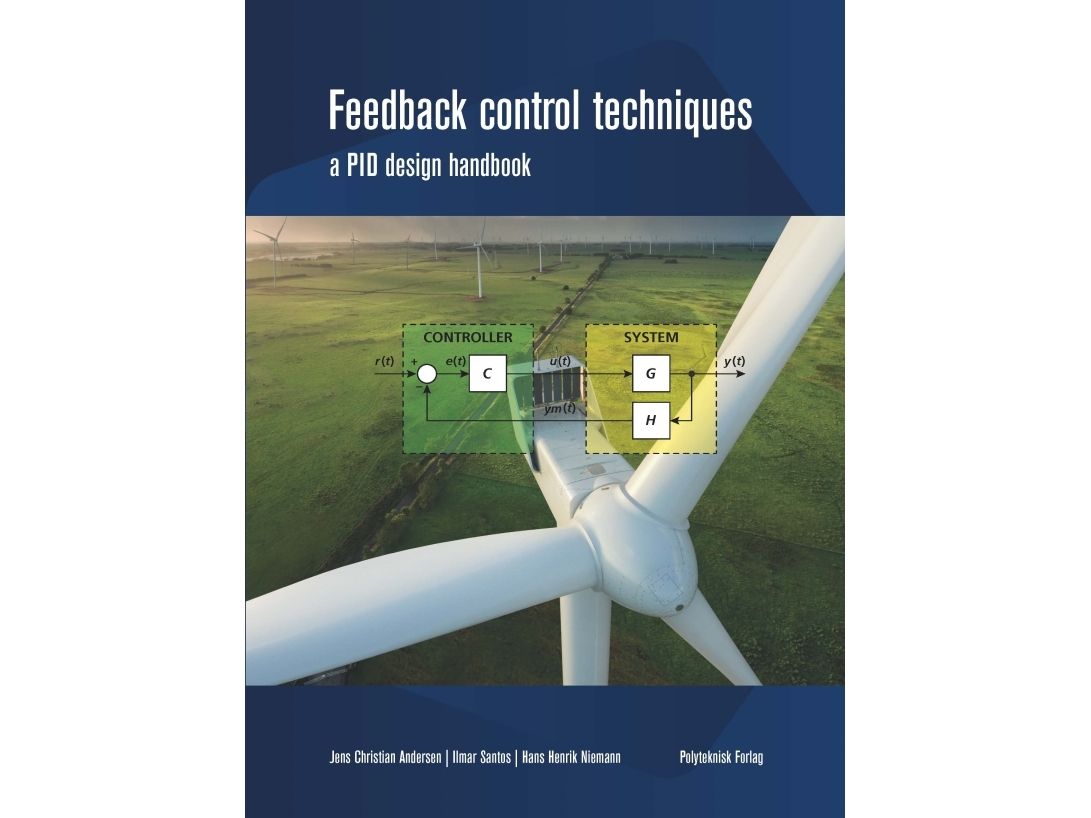
Feedback control techniques - a PID design handbook The authors’ intention is to promote an understanding of control loops, particularly PID (Proportional, Integral and Differential) based control loops, not just the design tools. A control loop consists of a controller, a system to control and feedback from a measured output back to the controller. The system could be controllable using, e.g. a valve or a motor voltage, and the output measurement could be, e.g. a temperature or a velocity. The controller is then to ensure that the output reaches the desired value. The book covers Laplace, transfer functions, modelling, controller design based on frequency analysis and handling of stability, limited systems and disturbances. This textbook is intended for a course in PID-type control design for engineering students at the university level. The chapters are intended to be self-contained, i.e. limiting the reference to earlier chapters, to allow chapters to be skipped if competencies covered by these chapters are obtained elsewhere. The independent chapters allow the book to be used for self-study and as a handbook. In one of the last chapters, z-transform is introduced briefly to allow the frequency domain controller design to be digitally implemented.
Originalsprog
Engelsk
Oplag
1
Udgivelsesdato
2022-07-28
Forfatter
Jens Christian Andersen, Henrik Niemann, Ilmar Santos
Sprog
Dansk
Sideantal
424
Indbinding
Indbundet
Udgave
1
Forlag
Polyteknisk Forlag
ISBN13
9788750200895
Tema gruppe(r)
Automatisk styringsteknik og reguleringsteknik,Maskinteknik
Produktet er kendt under følgende varenumre i vores system
SKU:
9788750200895
EAN:
9788750200895
Hvorfor oplever jeg at den umiddelbart samme vare findes på forskellige varenumre?
Producenterne udgiver ofte den samme vare med forskellige varenumre, typisk handler det udelukkende om forskellige versioner af emballagen. Eksempelvis kan emballagen være målrettet forskellige lande.
Vi forsøger bedst muligt at samle varerne, men det kan opleves at den samme vare figurerer på forskellige varenumre i vores system.